Legged mobility
A six-legged form is proposed for narrow rows and uneven surfaces, subject to field testing.
Six-legged Spider Autonomously Navigates Through Dense Farmland
AI Pest Detection and Crop Diagnosis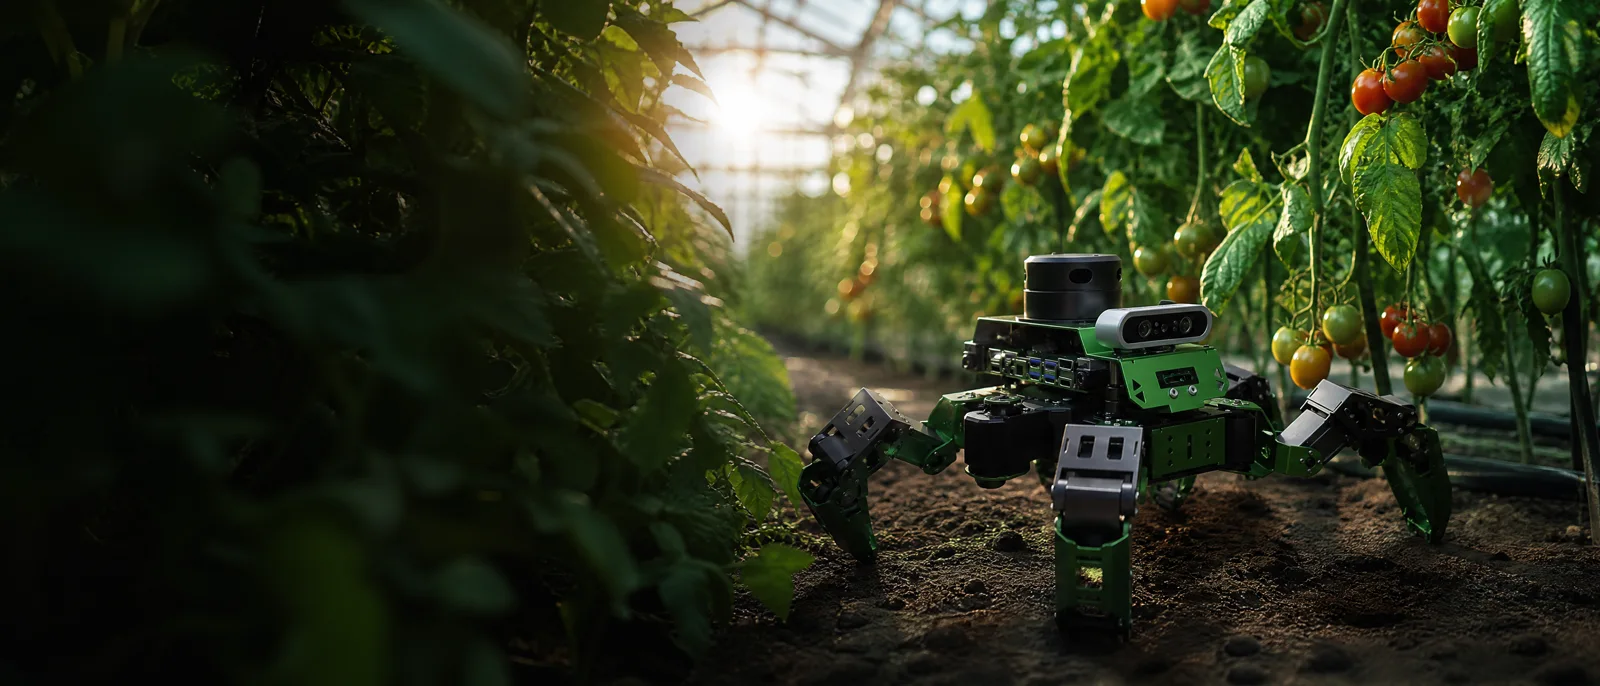
Six-legged Spider Autonomously Navigates Through Dense Farmland
The Spider concept is designed to use LiDAR and a depth camera to map uneven farm terrain and plan a stable path for its six-legged chassis. A relative-positioning GPS module will help plan efficient routes and make the most of available range, whilst allowing the farmer to know where it is at all times.
Design intentions, not verified field capabilities. Grower needs and real-world testing will shape the final system.
A six-legged form is proposed for narrow rows and uneven surfaces, subject to field testing.
The robot would carry imaging and sensing hardware to gather observations near the plant.
The intended workflow links an observation to the place where a grower can investigate it.
Prototype mobility, navigation, and crop-safe movement before making performance claims.
Explore the full approach